TL;DR: PROFINET is Siemens' industrial Ethernet protocol — a flexible, open standard for connecting PLCs to drives, I/O modules, and sensors across a plant network, with optional isochronous real-time (IRT) mode for motion applications. EtherCAT (Ethernet for Control Automation Technology) is Beckhoff's ultra-high-speed fieldbus that processes Ethernet frames on-the-fly as they traverse slave nodes, delivering cycle times as low as 100 microseconds for 100+ axis servo systems. PROFINET covers general plant integration. EtherCAT targets the highest-performance motion control applications.
Both protocols run on standard Ethernet hardware — Cat 5e cable, RJ-45 connectors, and Ethernet switches. But under that common physical layer, the architectures are fundamentally different. PROFINET uses standard IP-based communication with real-time extensions. EtherCAT processes frames without stopping at each node — a hardware technique that gives it performance no traditional Ethernet protocol can match.
PROFINET — Plant Integration with Real-Time Options
PROFINET (Process Field Net) is the industrial Ethernet standard developed by Siemens and the PROFIBUS and PROFINET International (PI) organization. It is the successor to PROFIBUS DP and is the primary fieldbus in Siemens TIA Portal projects.
PROFINET communication classes
PROFINET provides three communication channels with increasing real-time performance:
NRT (Non-Real-Time): standard TCP/UDP/IP communication — parameter reads, configuration, diagnostics. No timing guarantee. Used for device discovery, I&M (identification and maintenance) data, and alarm records.
RT (Real-Time): PROFINET's standard cyclic I/O channel — bypasses TCP/IP for lower latency. Typical cycle times: 1–10 ms. This mode runs on unmanaged switches without special hardware and covers most motion and I/O applications.
IRT (Isochronous Real-Time): hardware-synchronised cyclic I/O with jitter below 1 microsecond. Requires IRT-capable switches (Scalance X series or equivalent). Cycle times: 250 microseconds–4 ms. Used for high-performance servo drives (SINAMICS with PROFINET IRT) and CNC applications requiring axis synchronization.
PROFINET device model
PROFINET devices are described by GSDML files (General Station Description Markup Language — XML format). The GSDML lists the device's modules, submodules, and I/O data formats. When you add a device in TIA Portal, you import its GSDML and the tool configures the cyclic data exchange automatically.
Each device has a unique station name (not an IP address) used for identification during commissioning. The PLC assigns IP addresses to PROFINET devices at startup via DCP (Discovery and basic Configuration Protocol).
PROFINET strengths
- Native integration in Siemens TIA Portal and Step 7.
- Large installed base — Siemens S7-1200, S7-1500, S7-300/400, SINAMICS drives all speak PROFINET.
- Runs on standard managed or unmanaged Ethernet switches (for RT mode).
- Shared network with standard IT Ethernet traffic — PROFINET and OPC UA share the same cables.
- Strong device ecosystem — hundreds of vendors supply PROFINET I/O modules, drives, and sensors.
EtherCAT — On-the-Fly Frame Processing
EtherCAT was developed by Beckhoff Automation and is managed by the ETG (EtherCAT Technology Group). It is an open standard (IEC 61158, IEC 61784) used by Beckhoff, Omron, Yaskawa, Kollmorgen, and many others.
How EtherCAT works
Standard Ethernet sends a frame to one destination; the switch routes it to the right port; the destination processes it and sends a response. This full stop-and-respond adds latency at each node.
EtherCAT eliminates this. A single Ethernet frame — called a telegram — is sent by the master and passes through every slave node in a ring or line topology. Each slave reads its input data and writes its output data into the frame as it passes through the slave's hardware, in nanoseconds, without stopping the frame. The telegram returns to the master with all slaves' data collected and all outputs already written — in a single Ethernet cycle.
This "processing on the fly" architecture means:
- A 100-axis EtherCAT system can complete one full I/O cycle in under 300 microseconds.
- Jitter (timing variation) is below 1 microsecond without special switches.
- EtherCAT does not need managed switches — the master's Ethernet port connects directly to the first slave; slaves connect daisy-chain.
EtherCAT addressing
EtherCAT slaves are addressed by their physical position in the ring (auto-increment address) or by a configured station address (fixed address). There is no IP address or MAC-level routing — EtherCAT frames carry a protocol identifier (EtherType 0x88A4) that standard IP switches do not process.
This means EtherCAT cannot share a standard Ethernet network with normal IP traffic. The EtherCAT master port must be a dedicated NIC connected only to EtherCAT slaves. This is the most important constraint to understand before choosing EtherCAT.
Distributed clocks — the synchronization mechanism
EtherCAT's distributed clock mechanism synchronizes all slave clocks to sub-microsecond accuracy. The master propagates a reference timestamp through the ring; each slave measures the propagation delay and corrects its local clock. All slave outputs update at exactly the same tick — critical for multi-axis cam and gantry synchronization.
Side-by-Side Comparison
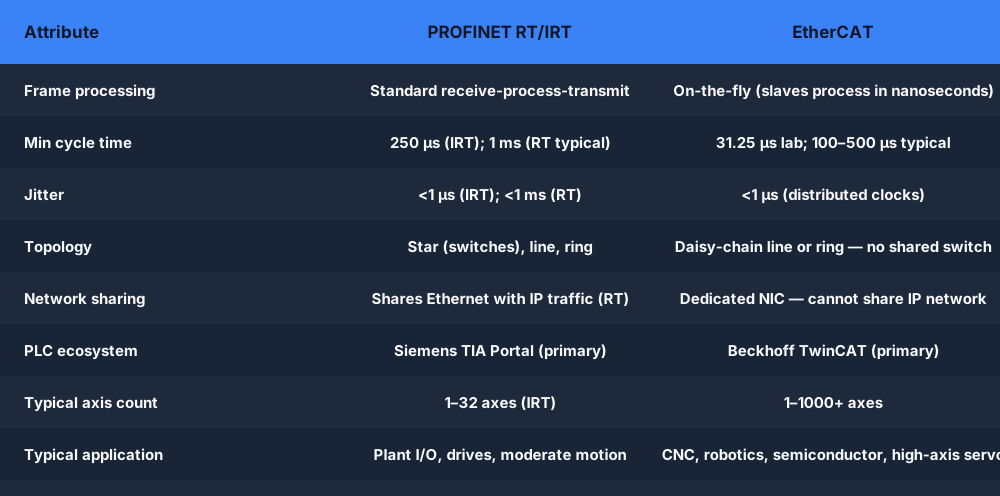
| PROFINET RT/IRT | EtherCAT | |
|---|---|---|
| Developer | Siemens / PI organization | Beckhoff / ETG |
| Standard | IEC 61158, IEC 61784 | IEC 61158, IEC 61784 |
| Frame processing | Standard receive-process-transmit | On-the-fly (slaves process frames in ns) |
| Minimum cycle time | 250 µs (IRT); 1 ms (RT typical) | 31.25 µs (typical 100–500 µs for large systems) |
| Jitter (IRT/EtherCAT) | <1 µs (IRT); <1 ms (RT) | <1 µs (distributed clocks) |
| Topology | Star (switches), line, ring | Line, ring — daisy-chain; NO shared switch |
| Network sharing | Shares Ethernet with IP traffic (RT) | Dedicated NIC — cannot share IP network |
| Addressing | Station name → IP address via DCP | Physical position or station address |
| Device description | GSDML (XML) | ESI (EtherCAT Slave Information, XML) |
| Synchronization | IRT hardware sync; RT free-running | Distributed clocks (<1 µs all axes) |
| PLC ecosystem | Siemens TIA Portal (primary) | Beckhoff TwinCAT (primary), many others |
| Typical axis count | 1–32 axes (IRT common range) | 1–1000+ axes |
| Typical application | Plant I/O, drives, multi-axis to ~32 | CNC, robotics, semiconductor, high-axis servo |
Decision Guide
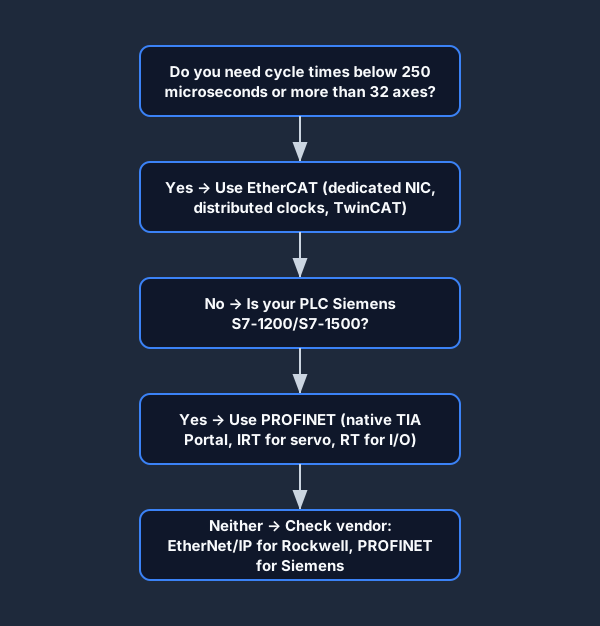
Use PROFINET when:
- Your PLC is Siemens (S7-1200, S7-1500) and your drives are SINAMICS — native TIA Portal integration.
- The application is general plant I/O, standard conveyor control, or moderate-performance motion (cycle times above 1 ms).
- You need to share the Ethernet network with OPC UA, standard IT traffic, or a SCADA server.
- You have up to 16–32 synchronized servo axes and IRT mode covers the synchronization requirement.
- The installed base is PROFIBUS DP and you are migrating to PROFINET on the same cabling infrastructure.
Use EtherCAT when:
- You need cycle times below 250 microseconds — CNC interpolation, semiconductor wafer handling, high-speed pick and place.
- You have a large axis count (50–1000+ axes) that needs microsecond synchronization.
- The controller is Beckhoff TwinCAT or an EtherCAT-native motion controller.
- The application is robotics, printing presses, packaging machines, or test and measurement requiring deterministic sub-millisecond I/O.
- You can dedicate a NIC and a cable run solely to the EtherCAT network.
Consider both when:
- A machine has an EtherCAT servo axis network (Beckhoff TwinCAT) and connects to a Siemens plant SCADA via PROFINET — a common architecture in European automotive plants. The EtherCAT master acts as a PROFINET I/O device presenting axis data to the Siemens line PLC.
Frequently Asked Questions
Q: Is EtherCAT faster than PROFINET?
A: At peak performance, yes — EtherCAT achieves cycle times of 31.25 microseconds in lab conditions. PROFINET IRT's practical minimum is about 250 microseconds. For typical plant automation with 4–16 axes at 1 ms cycles, PROFINET IRT and EtherCAT both perform well. EtherCAT's advantage becomes clear above 32 axes or below 500 microsecond cycle times.
Q: Can PROFINET and EtherCAT coexist on the same machine?
A: Yes, with a gateway. A Beckhoff EtherCAT master can expose its axis data over PROFINET as a PROFINET I/O device, allowing a Siemens PLC to supervise it. Some drive vendors supply hardware that speaks both protocols simultaneously — EtherCAT for the real-time axis network and PROFINET for the plant-level PLC connection.
Q: Does EtherCAT work with Siemens PLCs?
A: Not natively. Siemens STEP 7 and TIA Portal do not include an EtherCAT master. Siemens machines use PROFINET as the fieldbus. EtherCAT is native to Beckhoff TwinCAT and other non-Siemens motion controllers. Connecting a Siemens PLC to EtherCAT slaves requires a third-party EtherCAT master gateway.
Q: What is the difference between PROFINET and PROFIBUS?
A: PROFIBUS DP is the earlier generation — RS-485 serial fieldbus with token-ring bus topology, speeds up to 12 Mbit/s. PROFINET is its Ethernet-based successor — standard Cat 5e/Cat 6 cabling, RJ-45 connectors, and speeds of 100 Mbit or 1 Gbit. PROFINET carries the same device configuration concepts (GSD replaced by GSDML) and is backward-compatible via proxy devices for legacy PROFIBUS slaves.
Q: What is PROFINET IRT and when do I need it?
A: PROFINET IRT (Isochronous Real-Time) adds hardware-synchronised scheduling at the switch level, giving jitter below 1 microsecond. You need IRT for multi-axis servo applications where axes must update at exactly the same instant — electronic cams, gantry control, coordinated multi-axis CNC. IRT requires IRT-capable switches (such as Siemens Scalance X with IRT) and IRT-capable drives. Standard RT mode (using any managed switch) covers most conveyor and single-axis applications.
For hands-on practice with drive communication concepts — speed references, run commands, and fault handling in ladder logic — try the VFD conveyor speed scenario and the VFD fault reset scenario. The Ethernet/IP wiring lab covers the Ethernet physical layer that both PROFINET and EtherCAT share.