Runnable simulator field guide
VFD conveyor-speed PLC scenario: test checklist
Direct answer
The learner can distinguish run command, speed reference, drive ready or running state and actual conveyor response, then diagnose the first disagreeing boundary.
Written for pLC and drive learners controlling a conveyor with run permissives, a bounded speed reference and independent motion feedback.
Scenario setup
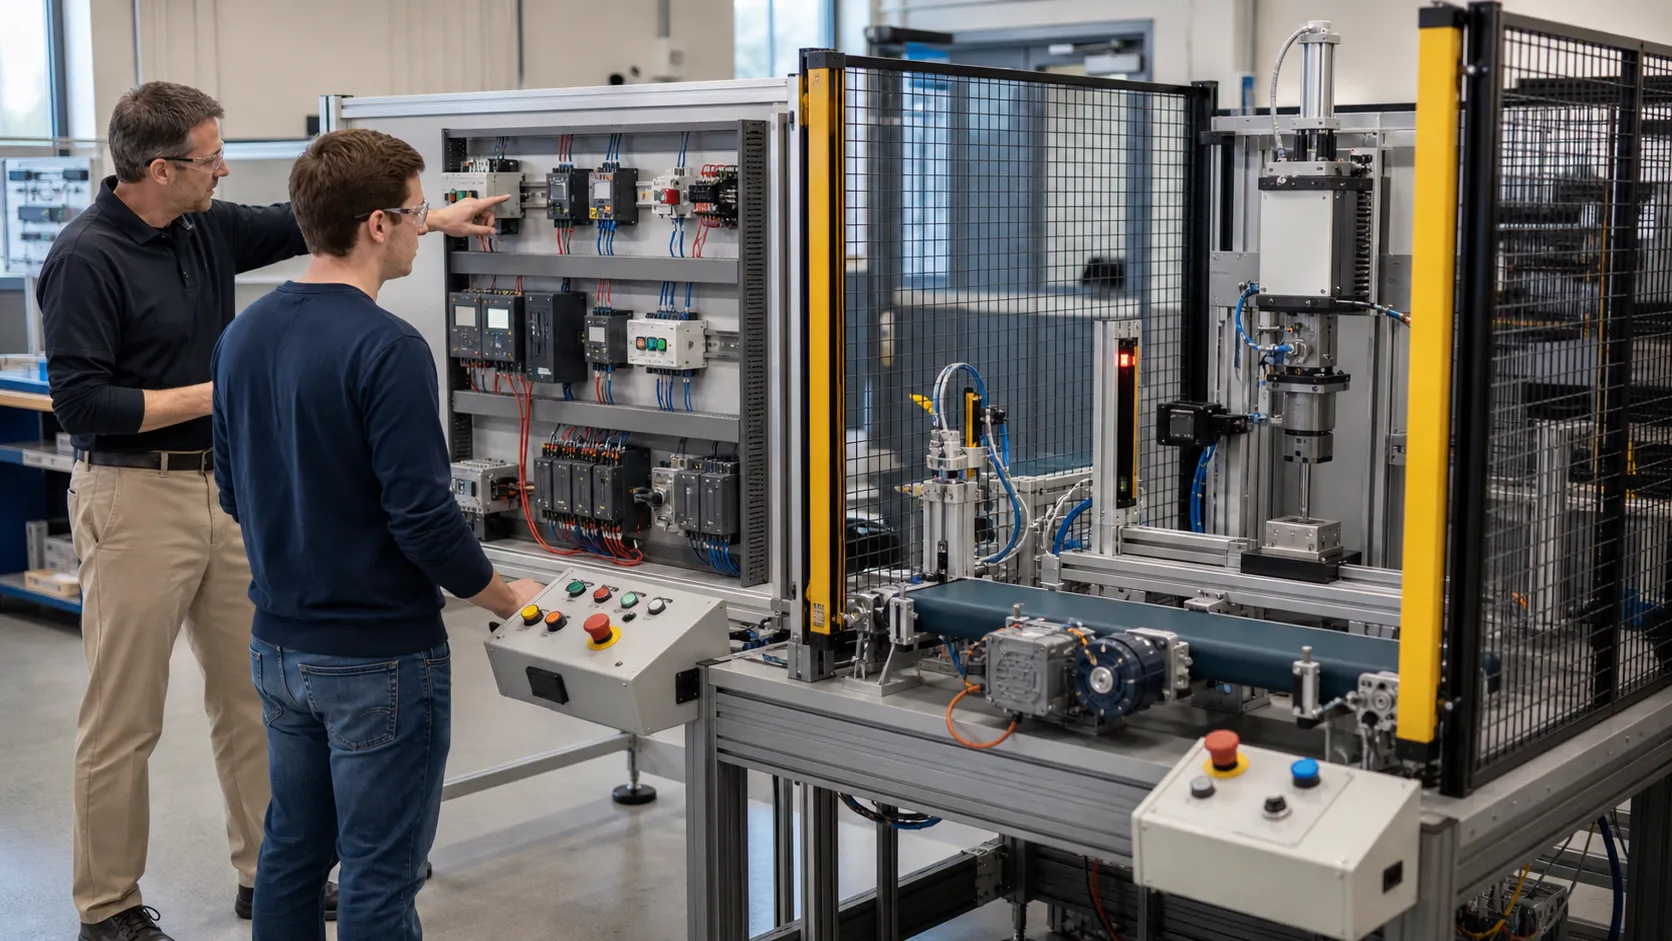
Conveyor duty, guarding boundary, run permissives, drive ready, command source, frequency or speed reference, minimum and maximum, ramps, motor data, feedback, trip and restart policy.
I/O and state map
Operator or sequence demand through PLC interlocks, drive run command and reference to output frequency, motor torque, belt motion, measured speed and process result.
Normal run
A permitted start accelerates to the bounded reference and stop returns the conveyor to the declared state with coherent feedback.
Boundary run
Zero reference, minimum and maximum, reversed direction, missing feedback, overload, jam, trip, communication loss, stop demand and power return.
Injected fault
A permissive, ownership, command, reference, drive-state, motor, belt, feedback, trip or restart mismatch.
Target check
The application validated on guarded target equipment with current drive data, risk controls and supervised acceptance tests.
Why can a VFD show running while a conveyor is stopped?
The drive command and output can exist while the motor, coupling, belt, load or speed-feedback path fails downstream.
Should conveyor speed be proved from the frequency reference?
No. A reference is a request; use drive output evidence and independent conveyor or process feedback for the required result.