KUKA robots are programmed in KRL — the KUKA Robot Language — using the smartPAD teach pendant and KUKA.Sim for offline work. Before you touch KRL, you have to understand the universal robot-programming fundamentals: frames and TCP, joint vs linear motion, waypoints, I/O, and pick-and-place. Practise all of those hands-on in your browser, free to start — on a real-code robot simulator whose skills transfer straight to KUKA.
Honest note: our simulator is not a KUKA emulator and does not run KRL. It teaches the brand-independent fundamentals using real URScript on a UR-style arm — the concepts that carry over to KUKA and KRL.
KUKA industrial robots are programmed in KRL — the KUKA Robot Language. A KRL program is a sequence of motion and logic instructions: PTP for point-to-point joint motion, LIN for straight-line Cartesian motion, and CIRC for circular motion, alongside variables, tool and base frame definitions, and digital I/O via $OUT[] and $IN[]. A KRL program is normally split across a .src motion file and a paired .dat data file, and the language is Pascal-style — close in feel to Structured Text. These programs run on the KUKA KR C controller (KRC4 / KRC5).
Day to day, a KUKA programmer works at the smartPAD, KUKA’s teach pendant — touchscreen, 6D jogging mouse, mode selector, and three-position enabling switch. You jog the arm, teach points, set the tool centre point and base frames, and step through the program. For larger jobs, integrators develop offline in KUKA.Sim (3D cell modelling, reach-checking, and cycle-time estimation), configure the controller and I/O in WorkVisual, and test programs on a PC with the OfficeLite virtual KR C controller before deploying to a real robot.
All of that — KRL syntax, the smartPAD, KUKA.Sim, WorkVisual — sits on top of one shared foundation: the way an articulated robot arm actually moves. That foundation is what most beginners are really missing, and it is brand-independent.
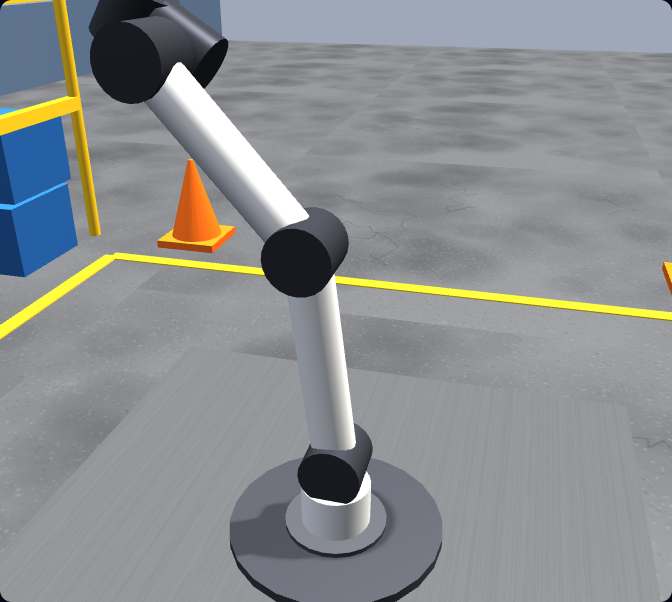
The same six-axis articulated kinematics behind a KUKA KR-series robot — joints A1–A6 — which you jog and program hands-on in the browser simulator.KUKA KRL is one vendor robot language among many — the motion concepts are shared; only the keywords (PTP/LIN/CIRC vs movej/movel) change.
What transfers
The fundamentals our simulator teaches — and where they land on a KUKA
You program our simulator in real robot code (URScript) on a six-axis arm. The keywords differ from KRL, but the concepts are the same articulated-arm fundamentals every KUKA programmer relies on.
Practiced in the simulator
On a real KUKA / in KRL
Joint vs linear motion (movej / movel)
PTP point-to-point vs LIN linear motion in KRL
Tool center point & payload setup
Tool frame and load data on the KR C controller
Base vs tool frames
BASE and TOOL coordinate frames in KRL
Waypoints & blend radius
Taught points and approximate (C_DIS / C_PTP) blends
Digital I/O & gripper control
OUT / IN signals driving the end-effector
Protective stop / force & speed limits
Safe operation and collaborative limits on KUKA cobots
Learn these once and moving to KRL is mostly relearning keywords, not relearning how a robot thinks. This mapping is conceptual — the simulator does not generate or run KRL or .src/.dat files; for that you would use a real smartPAD, KUKA.Sim, or WorkVisual.
Joint motion (KUKA PTP / URScript movej) takes the fast curved route through joint space; linear motion (KUKA LIN / movel) holds a straight Cartesian line. Choosing between them is a move-by-move decision on every KUKA program.Driving a gripper with digital outputs and reading inputs — the same I/O model as KUKA $OUT[] / $IN[] signals — to actually grasp and move a part.
An honest roadmap to KUKA
From zero to programming a KUKA — a realistic path
We will be straight with you: this site is not a KUKA emulator and will not make you a certified KRL programmer on its own. What it does is remove the most expensive, slowest step — building real robot-motion intuition — so the KUKA-specific layer is much faster to learn. Here is a path that works.
1
Build the fundamentals hands-on (here, free)
Program a six-axis arm in real code: frames, TCP, joint vs linear motion, waypoints, I/O, and a full graded pick-and-place cycle. This is the part that takes practice, and you can do it free in your browser.
2
Learn the KRL layer
With the concepts solid, map them onto KRL — PTP, LIN, CIRC, BASE and TOOL frames, and KUKA I/O. Reading and writing KRL is much faster once the underlying motion model is already familiar.
3
Get hands-on with KUKA tools
Practice in KUKA.Sim or OfficeLite, or on a real robot with the smartPAD. KUKA College courses and the official documentation cover the brand-specific details and safety procedures.
4
Specialize: cells, cobots, integration
Move into real applications — palletising, welding, machine tending, or collaborative assembly on an LBR iiwa — and the PLC and HMI side of a robot cell, which our PLC simulator covers.
WORLD, BASE and TOOL frames decide where the robot thinks it is — define the tool center point wrong and every taught KUKA point is off. Frames are step one of the fundamentals.Chaining waypoints with a blend radius for smooth, fast cycles — the same idea as KUKA approximate-positioning (C_PTP / C_DIS) blends instead of stop-start motion.
KUKA cobots
The LBR iiwa, iisy, and collaborative safety
KUKA’s collaborative robots include the LBR iiwa — seven axes (7-DOF) with integrated joint-torque sensing so it can work safely alongside people on sensitive assembly tasks — and the newer LBR iisy cobot family aimed at easy, plug-and-produce setup. KUKA also offers the KMR iiwa, an autonomous mobile platform that carries an LBR iiwa around a facility. Cobots add a safety layer on top of ordinary robot programming: force and speed limits, collision detection and response, and safe human collaboration.
Our simulator teaches the collaborative-safety mindset hands-on — protective stops, force limits, and keeping a pick-and-place cycle within safe contact limits — so that safety thinking carries over to a real KUKA cobot. Programming a seven-axis LBR iiwa in KRL adds its own specifics, but the safety fundamentals you build here are exactly the ones a collaborative cell demands.
Force and speed limits, safe zones and a protective stop on unexpected contact — the collaborative-safety discipline a KUKA LBR iiwa or iisy cobot cell demands, graded in the simulator.
Offline programming: model the cell, plan and reach-check paths, and validate a program away from the robot — the role KUKA.Sim, WorkVisual and OfficeLite play in a real KUKA workflow.
Offline programming
KUKA.Sim, WorkVisual and OfficeLite
Serious KUKA work happens offline before it ever reaches the floor. KUKA.Sim builds a 3D model of the cell so you can plan paths, reach-check, and estimate cycle time; WorkVisual configures the KR C controller, fieldbus and I/O, and safety, and deploys the KRL project; and OfficeLite runs a virtual KR C controller on a PC so you can test a program without hardware.
These are professional, KUKA-specific tools — and they all assume you already understand frames, the tool centre point, motion types, and I/O. That is exactly the layer our browser simulator builds first, so the day you open KUKA.Sim or WorkVisual you are learning the tool, not the fundamentals underneath it. See how a free browser sim compares to desktop offline-programming software.
What you practice
Hands-on, graded, in the browser
Every lesson is graded against a real goal, so you are not just watching an animation — you are building skill you can defend in an interview or on the floor.
Frames & TCP
Work in base vs tool frames and define the tool center point — the coordinate thinking behind every robot move, KUKA included.
Joint vs linear motion
When point-to-point joint motion is right and when you need a straight Cartesian line — the PTP-vs-LIN decision in KRL terms.
Waypoints & blends
Chain waypoints with blend radii for smooth, fast cycles instead of stop-start motion.
Digital I/O & gripper
Read and set digital signals to open and close a gripper and actually move a part.
Pick-and-place A→B
Approach, grasp, lift, traverse, place, release — the backbone of real robot work.
Collaborative safety
Protective stops, force limits, and safe contact — the cobot mindset the LBR iiwa demands.
The pick-and-place cycle — approach, grasp, lift, traverse, place, release — graded against a real goal. It is the backbone of palletising, machine tending and assembly on any KUKA cell.Payload at the tool changes reach, accuracy and safe speed — the same load-data thinking you configure on a KUKA KR C controller.
Prove the fundamentals
A graded path you can show an employer
Working through the fundamentals here is not just practice — it is a path. Go from your first jog, through frames, motion, I/O and a full graded pick-and-place, to a certificate of completion you can put on a CV or take into an interview as evidence you understand how a robot is programmed. None of it is KUKA-specific, and that is the point: it proves the brand-independent foundation a KUKA employer expects you to already have before you learn KRL.
KUKA industrial robots are programmed in KRL — the KUKA Robot Language. You typically jog the arm and teach points with the smartPAD teach pendant, then write or refine a KRL program (PTP, LIN, and CIRC motion commands, plus I/O and logic) that the KR C controller executes. Programs can be built directly on the controller or developed offline in KUKA.Sim and loaded onto the robot. The everyday workflow — define frames and a tool center point, teach waypoints, choose joint vs linear motion, drive I/O for a gripper, and build a pick-and-place cycle — is the same set of fundamentals our browser simulator teaches hands-on.
KRL stands for KUKA Robot Language, the proprietary programming language used to write motion and logic programs for KUKA industrial robots. A KRL program uses motion instructions such as PTP (point-to-point joint motion), LIN (linear Cartesian motion), and CIRC (circular motion), along with variables, frames, tool and base definitions, and I/O control. KRL runs on the KUKA KR C controller. Our simulator does not run KRL, but it teaches the underlying motion model — joint vs linear moves, frames, and TCP — so the KRL syntax makes sense the first time you read it.
KUKA.Sim is KUKA’s official offline simulation and programming software for the desktop. It lets integrators model a robot cell in 3D, plan and reach-check robot paths, estimate cycle times, and generate programs offline before deploying to a physical robot — KUKA also offers OfficeLite, a virtual KR C controller for testing programs on a PC. KUKA.Sim is professional integrator software, not a free learn-from-zero tool. Our browser simulator is the opposite end of that spectrum: free to start, install-free, and built to teach the fundamentals before you sit down in front of KUKA.Sim or a real smartPAD.
You can learn the fundamentals online for free, and that is the fastest on-ramp. Full KUKA-specific KRL training usually means KUKA College courses or access to a robot, smartPAD, or KUKA.Sim license. But the concepts that actually take time to internalise — frames and TCP, joint vs linear motion, waypoints and blends, digital I/O for a gripper, pick-and-place, and collaborative safety — are brand-independent. Our simulator lets you practice all of those hands-on in your browser, free to start, using real robot code on a simulated arm. Those skills transfer straight to KUKA and KRL.
The fundamentals transfer; the exact syntax does not. KUKA uses KRL (PTP, LIN, CIRC) and Universal Robots use URScript (movej, movel, movep), so the keywords differ. But both are six-axis articulated arms, and the underlying concepts are identical: defining a tool center point and payload, working in base vs tool frames, choosing joint motion versus straight-line Cartesian motion, chaining waypoints, driving I/O to operate a gripper, and respecting collaborative force and speed limits. Learn those on one arm and you mostly just relearn the keywords on the other. That is exactly why a UR-based fundamentals simulator is a useful path toward KUKA.
They are KUKA’s three core motion types. PTP (point-to-point) moves all axes together to reach a target by the fastest route through joint space, so the tool path through Cartesian space is curved and not directly predictable — it is the quickest way to get from A to B when the exact path does not matter. LIN moves the tool center point along a geometrically exact straight Cartesian line, which is what you want for welding, dispensing, or inserting a part. CIRC traces a circular arc defined by an auxiliary point and an end point. In Universal Robots / URScript terms that maps to movej (PTP), movel (LIN), and movep / arc moves (CIRC). Our simulator teaches the joint-vs-linear decision hands-on, which is exactly the PTP-vs-LIN judgment a KUKA programmer makes on every move.
WorkVisual is KUKA’s engineering and configuration environment for the KR C controller. It is where integrators configure the controller, set up fieldbus and I/O, manage safety configuration, and edit and deploy KRL projects to the robot — it complements KUKA.Sim (3D offline simulation and path planning) and OfficeLite (a virtual KR C controller for running programs on a PC). WorkVisual is professional KUKA-specific software; our browser simulator sits a step earlier, teaching the motion and I/O fundamentals so the WorkVisual and KRL layers make sense once you reach them.
A KRL program is normally split across two files that share a name: a .src motion/logic file that holds the actual instructions (PTP, LIN, CIRC, I/O, loops) and a .dat data file that holds the point and variable declarations the .src file uses. KRL itself is a Pascal-style structured language, so it reads much like Structured Text (ST) in IEC 61131-3 PLC programming. Our simulator does not produce .src/.dat files, but the program structure it teaches — define your points and tool, then sequence moves and I/O into a cycle — is the same shape you will recognize the first time you open a KRL .src file.
The KUKA LBR iiwa is a collaborative robot (cobot) with seven axes (7-DOF) and integrated joint-torque sensing, designed to work safely alongside people on sensitive assembly tasks. KUKA also makes the KMR iiwa mobile platform, which mounts the LBR iiwa on an autonomous mobile base. Cobots add a safety dimension on top of normal robot programming — force and speed limits, collision response, and safe collaboration. Our simulator teaches collaborative-safety fundamentals (protective stops, force limits, safe pick-and-place) so the safety mindset carries over to a real KUKA cobot, even though programming a seven-axis LBR iiwa in KRL adds its own specifics.
Build the robot fundamentals that transfer to KUKA.
Frames, TCP, joint vs linear motion, waypoints, I/O, pick-and-place, and collaborative safety — hands-on, graded, in your browser. Free to start.
The learner can describe one pick-and-place by base and tool frames, points, motion types, speed, approximation, I/O handshake and interruption recovery.
Written for robot and PLC programmers learning transferable industrial robot concepts before using official KUKA tools and a safeguarded cell.
System map / 02
NODE 01observable
01
Platform context
Controller and software generation, KRL context, base, tool, load data, points, PTP and linear motion, approximation, I/O, submit or program state and safety boundary.
NODE 02observable
02
Tags and addressing
Program statements through frames, interpolation and controller state to robot motion, gripper I/O, PLC handshake, process feedback and recoverable cell state.
NODE 03observable
03
Reference pattern
Home, approach, pick, depart, place and return behavior executes at deliberate training speed with explicit handshake evidence.
NODE 04observable
04
Timing and limits
Undefined frame, wrong load, unreachable point, singularity, approximation near process, lost grip, safety stop, interruption, manual recovery and restart.
NODE 05observable
05
Diagnostics
A program, frame, tool, load, point, motion, I/O, handshake, safety-state or recovery mismatch.
NODE 06observable
06
Official-tool transfer
The program recreated, simulated and accepted in current official KUKA tools and the safeguarded target cell.
Answer surface / 07
Q01
What language do KUKA robots use?
Many KUKA industrial controller families use KUKA Robot Language, but exact syntax, options and workflow depend on controller and software generation.
Q02
Can I learn KUKA programming without a robot?
You can learn frames, motion selection, state, I/O and recovery concepts in simulation; exact KRL, paths, loads, safety and deployment require official tools and supervised target-cell work.