Basic
20 min

Two-Speed Motor Control

motortwo-speedinterlocksafety

Ready to build this?

Sign up free — no credit card required. This scenario requires the Basic plan.

Sign up to play this scenario →

Already have an account? Log in

Two-Speed Motor Control scenario preview

Briefing

A two-speed (Dahlander or separate windings) motor starter. HIGH_PB runs the motor at high speed; LOW_PB at low speed. The two contactors are interlocked — only one can be energised at a time. Changing speed requires pressing STOP_PB first (direct high-to-low or low-to-high switching is not permitted, preventing winding damage). ESTOP drops both contactors immediately.

Objectives

  • HIGH_PB seals in HIGH_CONTACTOR (while stopped and no fault)
  • LOW_PB seals in LOW_CONTACTOR (while stopped and no fault)
  • STOP_PB de-energises the active contactor
  • Direct speed change without STOP is inhibited — pressing HIGH while low is running does nothing
  • ESTOP drops both contactors and latches FAULT_LAMP
  • RUN_LAMP on while either speed is running

Hints

  • HIGH_BIT: S= by HIGH_PB AND /LOW_BIT; R= by STOP_PB or /ESTOP
  • LOW_BIT: S= by LOW_PB AND /HIGH_BIT; R= by STOP_PB or /ESTOP
  • HIGH_CONTACTOR := HIGH_BIT AND /FAULT_BIT; LOW_CONTACTOR := LOW_BIT AND /FAULT_BIT
  • FAULT_BIT: S= by /ESTOP; R= by STOP_PB AND ESTOP

I/O Table

Inputs

HIGH_PB

High speed push-button (momentary)

BOOL · %I0.0

LOW_PB

Low speed push-button (momentary)

BOOL · %I0.1

STOP_PB

Stop push-button (momentary)

BOOL · %I0.2

ESTOP

E-stop (NC — true=healthy)

BOOL · %I0.3

Outputs

HIGH_CONTACTOR

High-speed winding contactor coil

BOOL · %Q0.0

LOW_CONTACTOR

Low-speed winding contactor coil

BOOL · %Q0.1

RUN_LAMP

Running indicator lamp (either speed)

BOOL · %Q0.2

Your program will be tested against:

All test cases run automatically when you submit. Assertions are hidden until you pass.

  1. #1HIGH_PB seals in HIGH_CONTACTOR

    Momentary HIGH_PB seals in high-speed contactor; STOP drops it

  2. #2LOW_PB seals in LOW_CONTACTOR

    Momentary LOW_PB seals in low-speed contactor

  3. #3Cannot switch from high to low without STOP first

    Pressing LOW_PB while HIGH is running is inhibited — must STOP first

  4. #4ESTOP drops both contactors and latches fault

    E-stop de-energises all and latches fault; STOP_PB clears after ESTOP restored

Ready to build this?

Sign up free — no credit card required. This scenario requires the Basic plan.

Sign up to play this scenario →

Already have an account? Log in

Runnable simulator field guide

Two-speed motor PLC scenario: test checklist

Direct answer

The learner can prove stop priority, prevent overlapping speed outputs, transition through the declared stopped state and diagnose failed feedback.

Written for pLC and motor-control learners sequencing low and high speed with mutually exclusive commands and independent running evidence.
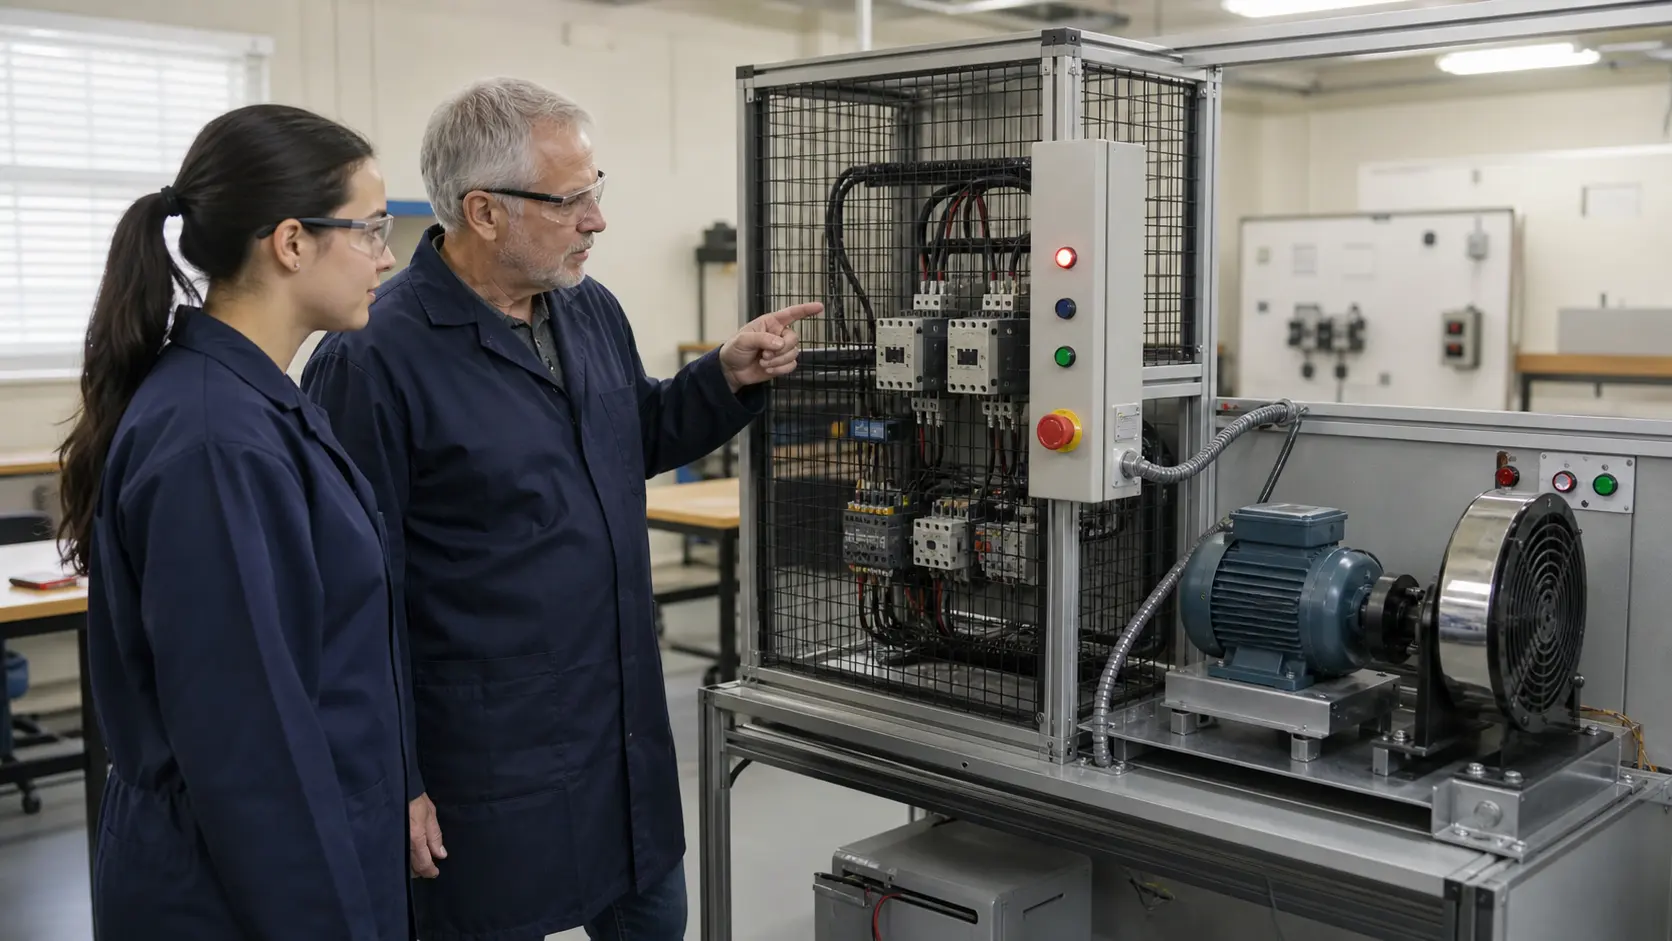
a guarded motor-control training cell with two-speed starter equipment, feedback and protective devices used for safe sequence verification while studying two-speed motor selection, mutual interlock, transition delay and feedback
System map / 02

NODE 01observable

Scenario setup

Motor and load, low and high requests, mode, stop priority, permissives, speed contactors or drive command, transition delay, feedback and overload state.

NODE 02observable

I/O and state map

Operator request through selection, interlocks and final output owner to starter or drive, motor speed and independent feedback.

NODE 03observable

Normal run

Each speed runs separately, Stop removes both commands and a speed change follows the declared transition without overlap.

NODE 04observable

Boundary run

Both requests, high selected from standstill, change while running, welded contact, failed feedback, overload, held start, power loss and restart.

NODE 05observable

Injected fault

A request, priority, selection, state, interlock, output, starter, drive, motor or feedback mismatch.

NODE 06observable

Target check

The logic validated with the exact motor, switching arrangement, protection and manufacturer transition rules.

Answer surface / 07

Can low-speed and high-speed contactors energize together?

Not unless the exact equipment is specifically designed for that state; typical two-speed control requires electrical, mechanical and software prevention of invalid overlap.

How should a PLC change motor speed?

Follow the approved motor or drive method, often removing the current command, proving the required transition state and then enabling the new speed after a bounded delay.